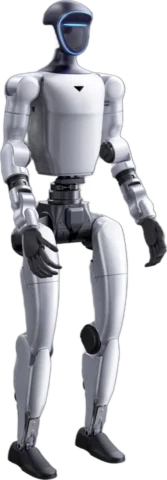
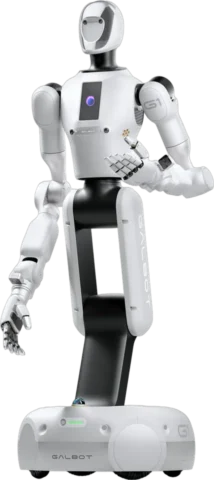
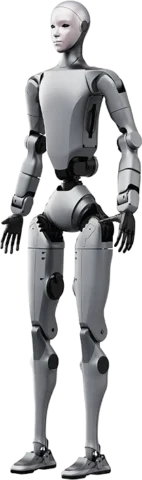
Astribot S1 vs ROBOTERA L7 vs Unitree H1
Price, availability in your region, size to scale and every spec side by side. Better values are marked; estimates never win.
Quick verdict
L7 wins 2 of the 4 specs where one robot is clearly better.
1
2
1
Choose S1 for
- Battery1,000 Wh
Choose L7 for
- Peak joint torque400 N·m
- HandsDexterous hands
Choose H1 for
- Top speed5 m/s
Size to scale
- Adult175 cm
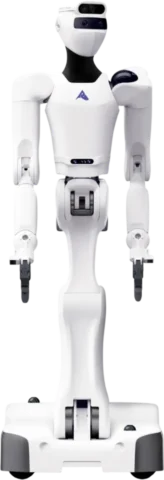 S1170 cm
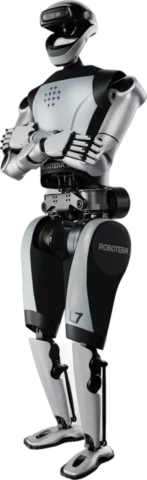 L7171 cm
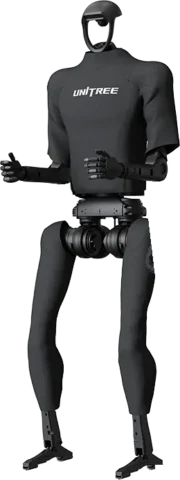 H1180 cm
All specs
| Spec | S1TBA | L7On request | H1On request |
|---|---|---|---|
| Where you can get it | |||
| United States | Not available | Not available | Business only |
| European Union | Ships to you€106,118 · DE €89,175 + 19 % VAT; varies by country | Ships to you€160,392 · DE €134,783 + 19 % VAT, RBTX Germany | Business only |
| United Kingdom | Ships to you£149,814 · £124,845 + 20 % VAT, RBTX UK | Ships to you£226,436 · £188,696 + 20 % VAT, RBTX UK | Business only |
| China | Ships to you¥1,007,678 · ¥891,750 + 13 % VAT, RBTX China | Ships to you¥1,523,049 · ¥1,347,831 + 13 % VAT, RBTX China | Business only |
| Japan and Korea | Ships to you | Ships to you | Business only |
| The rest of the world | Ships to you | Ships to you | Business only |
| Overview | |||
| Status | Shipping | Shipping | Shipping |
| Announced | Apr 2024 | Jul 2025 | Aug 2023 |
| Locomotion | Wheeled base | Two legs | Two legs |
| Form factor | Upper body | Full-size humanoid | Full-size humanoid |
| Autonomy | —Not published | —Not published | Programmed motions |
| Price | |||
| Price type | Official price | Quote only | Quote only |
| Price note | igus RBTX list price, varies by country; Astribot publishes no price | No maker list price; quote from ROBOTERA or via igus RBTX | Price on request from Unitree sales; dexterous hands optional |
| Size & body | |||
| Height | 170 cm | 171 cm | 180 cm |
| Weight | 80 kg | 65 kg | 47 kg |
| Shoulder width | —Not published | —Not published | 57 cm |
| Movement S1 0L7 1H1 1 | |||
| Degrees of freedom | 22calc. | 55 | 19calc. |
| DoF without hands | 20calc. | 31 | 19calc. |
| Top speed | —Not published | 4 m/s | 5 m/sbetter |
| Peak joint torque | 200 N·m | 400 N·mbetter | 360 N·m |
| Actuators | Tendon-driven | —Not published | Electric rotary |
| Hands & handling S1 0L7 1H1 0 | |||
| Hands | Simple gripper | Dexterous handsbetter | None |
| DoF per hand | —Not published | 12 | —Not published |
| Touch sensing | —Not published | Fingertips | —Not published |
| Carrying payload | —Not published | 20 kg | —Not published |
| Payload per arm | 5 kg | —Not published | —Not published |
| Battery & power S1 1L7 0H1 0 | |||
| Runtime | 4 h | —Not published | —Not published |
| Battery | 1,000 Whbetter | 900 Whcalc. | 864 Wh |
| Battery swap | —Not published | —Not published | Swappable by hand |
| Sensors | |||
| Cameras | Head stereo camera and RGB-D camera; RGB-D camera in the chest and in each gripper | Binocular camera | Intel RealSense D435i depth camera |
| Depth sensing | 4 RGB-D cameras (head, chest, 2 grippers); 2 LiDAR sensors in the chassis | Binocular depth camera, 3D LiDAR | Livox MID-360 3D LiDAR and Intel RealSense D435i depth camera |
| Audio | —Not published | Microphone array and speaker | —Not published |
| Compute & AI | |||
| Onboard computer | —Not published | 80 TOPS (x86) plus 275 TOPS (NVIDIA Orin) | Intel Core i5 (platform) and Intel Core i7 (user development); Orin NX optional |
| AI model | —Not published | ERA-42 (vision-language-action) | —Not published |
| Remote operation | Yes | —Not published | —Not published |
| Software | |||
| SDK | —Not published | —Not published | Open SDK |
| Languages & frameworks | —Not published | —Not published | C++ and Python (unitree_sdk2) |
| Simulation models | —Not published | —Not published | URDF (unitree_ros); Isaac Gym and MuJoCo (unitree_rl_gym) |
| Over-the-air updates | —Not published | —Not published | Yes |
| Safety & compliance | |||
| Intended use | Embodied-AI research, VR teleoperation data collection and service demonstrations | —Not published | Civilian robot for research and development |
A check marks the better value. Height and weight are context, not wins. Values marked "est.", "reported" or "calc." never count as wins. How we compare