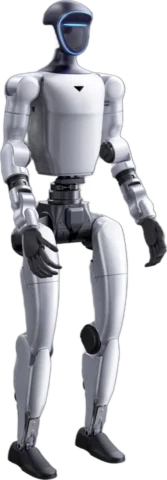
Boston Dynamics Atlas vs EngineAI T800 vs Unitree H1
Price, availability in your region, size to scale and every spec side by side. Better values are marked; estimates never win.
Quick verdict
Atlas wins 4 of the 6 specs where one robot is clearly better.
4
1
1
Choose Atlas for
- AutonomyPartly autonomous
- Degrees of freedom56
- HandsDexterous hands
- Battery swapSwaps itself
Choose T800 for
- Peak joint torque450 N·m
Choose H1 for
- SDKOpen SDK
Size to scale
- Adult175 cm
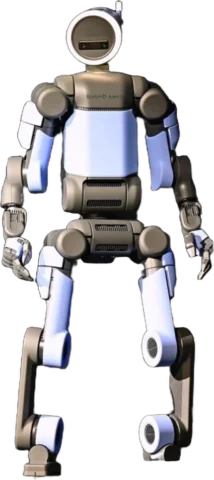 Atlas190 cm
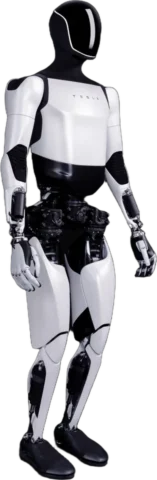
- T800173 cm
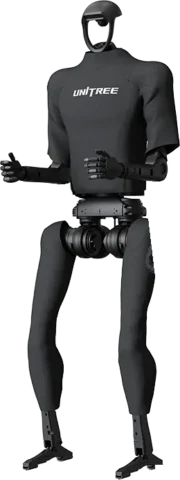 H1180 cm
All specs
| Spec | AtlasTBA | T800On request | H1On request |
|---|---|---|---|
| Where you can get it | |||
| United States | Business only | Not available | Business only |
| European Union | Not available | Not available | Business only |
| United Kingdom | Not available | Not available | Business only |
| China | Not available | Ships to you | Business only |
| Japan and Korea | Not available | Not available | Business only |
| The rest of the world | Not available | Not available | Business only |
| Overview Atlas 1T800 0H1 0 | |||
| Status | Pilot deployments | Shipping | Shipping |
| Announced | Jan 2026 | Dec 2025 | Aug 2023 |
| First deliveries | —Not published | May 2026 | —Not published |
| Locomotion | Two legs | Two legs | Two legs |
| Form factor | Full-size humanoid | Full-size humanoid | Full-size humanoid |
| Autonomy | Partly autonomousbetter | —Not published | Programmed motions |
| Price | |||
| Price type | Not announced | Quote only | Quote only |
| Price note | Not sold publicly; select enterprise early adopters | List prices removed in 2026; JD.com in China or sales inquiry | Price on request from Unitree sales; dexterous hands optional |
| Size & body | |||
| Height | 190 cm | 173 cm | 180 cm |
| Weight | 90 kg | 75 kg | 47 kg |
| Shoulder width | —Not published | —Not published | 57 cm |
| Vertical reach | 230 cm | —Not published | —Not published |
| Outer shell | —Not published | Aviation-grade aluminum and titanium alloy | —Not published |
| Movement Atlas 1T800 1H1 0 | |||
| Degrees of freedom | 56better | 25 | 19calc. |
| DoF without hands | —Not published | —Not published | 19calc. |
| Top speed | —Not published | —Not published | 5 m/s |
| Peak joint torque | —Not published | 450 N·mbetter | 360 N·m |
| Actuators | Electric rotary | Electric rotary | Electric rotary |
| Hands & handling Atlas 1T800 0H1 0 | |||
| Hands | Dexterous handsbetter | None | None |
| Touch sensing | Fingers and palms | —Not published | —Not published |
| Carrying payload | 30 kg | —Not published | —Not published |
| Payload per arm | 20 kg | —Not published | —Not published |
| Peak lift | 50 kg | —Not published | —Not published |
| Battery & power Atlas 1T800 0H1 0 | |||
| Runtime | 4 h | 4 h | —Not published |
| Battery | —Not published | —Not published | 864 Wh |
| Battery swap | Swaps itselfbetter | Swappable by hand | Swappable by hand |
| Charging | Self-docking | —Not published | —Not published |
| Battery swap time | 3 min | —Not published | —Not published |
| Charge time | 90 min | —Not published | —Not published |
| Charges itself | Yes | —Not published | —Not published |
| Sensors | |||
| Cameras | 360° camera view | Intel wide field-of-view binocular camera in the head | Intel RealSense D435i depth camera |
| Depth sensing | —Not published | Binocular camera only; 3D LiDAR on Open Source, Pro and Max editions | Livox MID-360 3D LiDAR and Intel RealSense D435i depth camera |
| Audio | —Not published | Microphone and speaker | —Not published |
| Compute & AI | |||
| Onboard computer | —Not published | 8-core RK3588S robot PC plus NVIDIA Jetson Orin NX 16 GB | Intel Core i5 (platform) and Intel Core i7 (user development); Orin NX optional |
| AI model | Large behavior models; Gemini Robotics models in joint research with Google DeepMind | —Not published | —Not published |
| Remote operation | Yes | —Not published | —Not published |
| Connectivity | —Not published | Wi-Fi 5, Bluetooth 5.0 | —Not published |
| Software Atlas 0T800 0H1 1 | |||
| SDK | —Not published | Closed | Open SDKbetter |
| Languages & frameworks | —Not published | —Not published | C++ and Python (unitree_sdk2) |
| Simulation models | —Not published | —Not published | URDF (unitree_ros); Isaac Gym and MuJoCo (unitree_rl_gym) |
| Over-the-air updates | —Not published | —Not published | Yes |
| Safety & compliance | |||
| Dust & water rating | IP67 | —Not published | —Not published |
| Intended use | Industrial material handling: part sequencing, machine tending, order fulfillment | Logistics and warehousing, hotel service, retail guidance and factory collaboration | Civilian robot for research and development |
| Support | |||
| Service | Field-replaceable limbs in under 5 minutes; customer self-repair certification | —Not published | —Not published |
A check marks the better value. Height and weight are context, not wins. Values marked "est.", "reported" or "calc." never count as wins. How we compare