Engineered Arts Ameca vs PAL Robotics TALOS vs Toyota T-HR3
Price, availability in your region, size to scale and every spec side by side. Better values are marked; estimates never win.
Quick verdict
Ameca wins 3 of the 3 specs where one robot is clearly better.
3
Choose Ameca for
- AutonomyPartly autonomous
- Degrees of freedom61
- DoF per hand4
Choose TALOS for
No outright win on sourced specs.
Choose T-HR3 for
No outright win on sourced specs.
Size to scale
- Adult175 cm
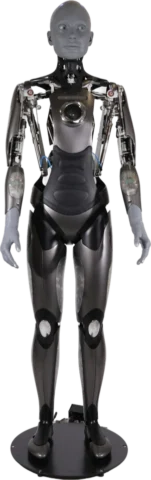 Ameca187 cm
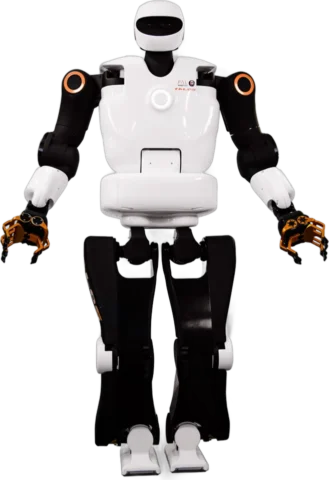 TALOS175 cm
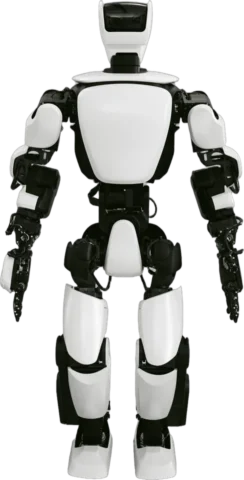 T-HR3154 cm
All specs
| Spec | AmecaOn request | TALOSOn request | T-HR3TBA |
|---|---|---|---|
| Where you can get it | |||
| United States | Business only | Business only | Not available |
| European Union | Business only | Business only | Not available |
| United Kingdom | Business only | Business only | Not available |
| China | Not available | Not available | Not available |
| Japan and Korea | Business only | Not available | Not available |
| The rest of the world | Business only | Business only | Not available |
| Overview Ameca 1TALOS 0T-HR3 0 | |||
| Status | Shipping | Shipping | Prototype |
| Announced | Jan 2022 | Feb 2017 | Nov 2017 |
| Locomotion | Stationary | Two legs | Two legs |
| Form factor | Upper body | Full-size humanoid | Full-size humanoid |
| Autonomy | Partly autonomousbetter | —Not published | Teleoperated |
| Price | |||
| Price type | Quote only | Quote only | Not announced |
| Price note | Quote only; no list price published | Request a quote from PAL Robotics; no list price published | Research prototype, no price announced |
| Size & body | |||
| Height | 187 cm | 175 cm | 154 cm |
| Weight | 62 kg | 95 kg | 75 kg |
| Outer shell | Neutral gray silicone face and hands, exposed mechanical frame | —Not published | —Not published |
| Movement Ameca 1TALOS 0T-HR3 0 | |||
| Degrees of freedom | 61better | 32 | 32 |
| DoF without hands | 53calc. | 30calc. | —Not published |
| Walking speed | —Not published | 0.8 m/s | —Not published |
| Actuators | —Not published | —Not published | Electric rotary |
| Hands & handling Ameca 1TALOS 0T-HR3 0 | |||
| Hands | Dexterous handsbetter | Simple gripper | Dexterous handsbetter |
| DoF per hand | 4better | 1 | —Not published |
| Payload per arm | —Not published | 6 kg | —Not published |
| Battery & power | |||
| Runtime | —Not published | 1.5 h | —Not published |
| Battery | —Not published | 1,080 Wh | —Not published |
| Charging | Tethered power | —Not published | —Not published |
| Sensors | |||
| Cameras | 2 × 8 MP cameras, one in each eye | RGB camera, 1280 x 720 at 30 fps, 60° x 49.5° field of view | —Not published |
| Depth sensing | 360° LiDAR safety sensors | Depth camera, 640 x 480 at 30 fps, 0.4–8 m range | —Not published |
| Audio | 2 ear microphones, 4-channel chest microphone, 20 W chest speaker | 5 W speaker, English text to speech | —Not published |
| Talks with people | Yes | —Not published | —Not published |
| Compute & AI | |||
| Onboard computer | —Not published | 2 × Intel Core i7 (COM Express Type-6), Ubuntu LTS with RT Preempt | —Not published |
| AI model | Tritium AI with default OpenAI ChatGPT, OpenAI Whisper and Amazon Polly integrations | —Not published | —Not published |
| Remote operation | Yes | —Not published | Yes |
| Connectivity | RJ45 Ethernet, 2 × Thunderbolt, 2 × USB, 2 × HDMI, 3.5 mm audio out | Wi-Fi 802.11 a/b/g/n, Ethernet, EtherCAT | Wired; 5G wireless link trialed with NTT DOCOMO in 2018 |
| Software | |||
| SDK | Partners only | —Not published | —Not published |
| Languages & frameworks | Python, Node.js, REST, WebSocket | —Not published | —Not published |
| Simulation models | —Not published | Gazebo and URDF model (open source) | —Not published |
| Safety & compliance | |||
| Certifications | CE | —Not published | —Not published |
| Emergency stop | Emergency stop buttons | —Not published | —Not published |
| Intended use | Social interaction, exhibitions, reception, research and education | Humanoid robotics research | Remote-operated humanoid research platform |
| Support | |||
| Warranty | 12 months | —Not published | —Not published |
A check marks the better value. Height and weight are context, not wins. Values marked "est.", "reported" or "calc." never count as wins. How we compare