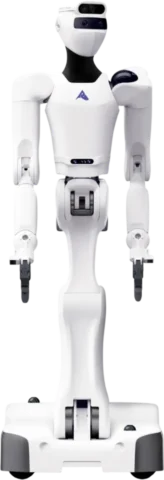
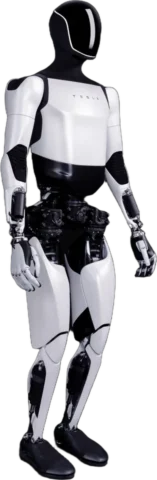
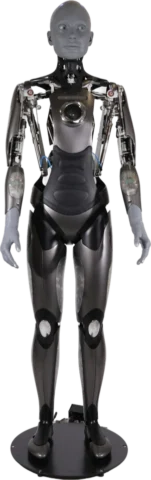
Galbot G1 vs Pollen Robotics Reachy 2 vs ROBOTERA L7
Price, availability in your region, size to scale and every spec side by side. Better values are marked; estimates never win.
Quick verdict
L7 wins 4 of the 6 specs where one robot is clearly better.
2
4
Choose G1 for
- AutonomyAutonomous tasks
- Payload per arm5 kg
Choose Reachy 2 for
No outright win on sourced specs.
Choose L7 for
- DoF without hands31
- Top speed4 m/s
- HandsDexterous hands
- Carrying payload20 kg
Size to scale
- Adult175 cm
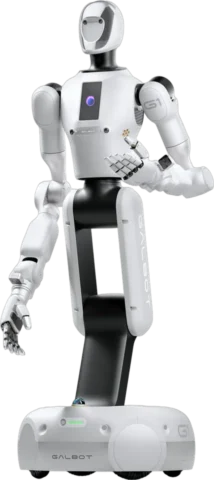 G1173 cm
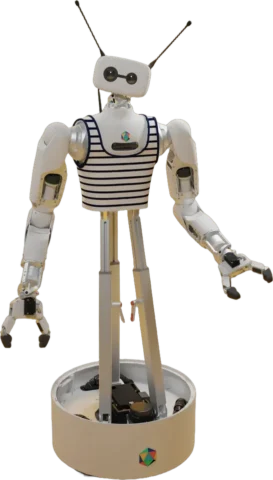 Reachy 2166 cm
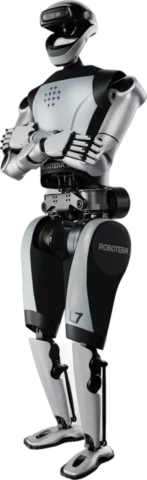 L7171 cm
All specs
| Spec | G1On request | Reachy 2On request | L7On request |
|---|---|---|---|
| Where you can get it | |||
| United States | Not available | Import only | Not available |
| European Union | Not available | Ships to you | Ships to you€160,392 · DE €134,783 + 19 % VAT, RBTX Germany |
| United Kingdom | Not available | Not available | Ships to you£226,436 · £188,696 + 20 % VAT, RBTX UK |
| China | Ships to you | Not available | Ships to you¥1,523,049 · ¥1,347,831 + 13 % VAT, RBTX China |
| Japan and Korea | Not available | Not available | Ships to you |
| The rest of the world | Not available | Not available | Ships to you |
| Overview G1 1Reachy 2 0L7 0 | |||
| Status | Shipping | Shipping | Shipping |
| Announced | Jun 2024 | 2024 | Jul 2025 |
| Locomotion | Wheeled base | Wheeled base | Two legs |
| Form factor | Upper body | Upper body | Full-size humanoid |
| Autonomy | Autonomous tasksbetter | Teleoperated | —Not published |
| Price | |||
| Price type | Quote only | Quote only | Quote only |
| Price note | No public price; JD.com listing in China | by quotation in EUR; $70,000 announced Apr 2025, configuration not stated | No maker list price; quote from ROBOTERA or via igus RBTX |
| Size & body | |||
| Height | 173 cm | 166 cm | 171 cm |
| Weight | 92.5 kg | 50 kg | 65 kg |
| Vertical reach | 210 cm | —Not published | —Not published |
| Movement G1 0Reachy 2 0L7 2 | |||
| Degrees of freedom | 23calc. | 21calc. | 55 |
| DoF without hands | 21 | 19calc. | 31better |
| Top speed | 1.5 m/s | —Not published | 4 m/sbetter |
| Peak joint torque | —Not published | —Not published | 400 N·m |
| Actuators | —Not published | Electric rotary | —Not published |
| Hands & handling G1 1Reachy 2 0L7 2 | |||
| Hands | Simple gripper | Simple gripper | Dexterous handsbetter |
| DoF per hand | —Not published | —Not published | 12 |
| Touch sensing | —Not published | —Not published | Fingertips |
| Carrying payload | 10 kg | —Not published | 20 kgbetter |
| Payload per arm | 5 kgbetter | 3 kg | —Not published |
| Battery & power | |||
| Runtime | 8 h | 8 h | —Not published |
| Battery | 1,440 Whcalc. | 840 Whcalc. | 900 Whcalc. |
| Charging | Plug-in charger | Plug-in charger | —Not published |
| Charge time | 210 min | —Not published | —Not published |
| Charges itself | Yes | —Not published | —Not published |
| Sensors | |||
| Cameras | Head binocular camera, 4 torso RGB cameras | 2× IMX296 global-shutter RGB cameras in the head; Orbbec Gemini 336 RGB-D camera in the torso | Binocular camera |
| Depth sensing | 2 wrist depth cameras; chassis 3D LiDAR and 8 ultrasonic sensors | Luxonis OAK-FFC ToF 33D (head), Orbbec Gemini 336 (torso), RPLidar S2 (base) | Binocular depth camera, 3D LiDAR |
| Audio | 2 × linear 4-mic arrays, 2 × 5 W speakers | 2 microphones in the antennas; custom speaker in the abdomen | Microphone array and speaker |
| Talks with people | Yes | —Not published | —Not published |
| Compute & AI | |||
| Onboard computer | NVIDIA AGX Orin 64GB | SolidRun Bedrock v3000 fanless CPU-based industrial PC; AI runs on external hardware | 80 TOPS (x86) plus 275 TOPS (NVIDIA Orin) |
| AI compute | 275 TOPS | —Not published | —Not published |
| AI model | Galbot AstraBrain embodied foundation model | —Not published | ERA-42 (vision-language-action) |
| Remote operation | —Not published | Yes | —Not published |
| Connectivity | Wi-Fi 2.4/5 GHz, Bluetooth 5.2, 2 × USB 3.0, HDMI | —Not published | —Not published |
| Software | |||
| SDK | Open SDK | Open SDK | —Not published |
| Languages & frameworks | Python, C++ | Python SDK, ROS 2 Humble | —Not published |
| Simulation models | Official G1 models in URDF, MJCF and USD | Gazebo, MuJoCo | —Not published |
| Over-the-air updates | —Not published | Yes | —Not published |
| Safety & compliance | |||
| Dust & water rating | IP54 | —Not published | —Not published |
| Emergency stop | Emergency stop button | Emergency stop button supplied | —Not published |
| Intended use | Retail, pharmacy and warehouse picking, industrial handling, education | AI and robotics research, teleoperation and manipulation data collection | —Not published |
| Support | |||
| Warranty | 12 months | —Not published | —Not published |
A check marks the better value. Height and weight are context, not wins. Values marked "est.", "reported" or "calc." never count as wins. How we compare