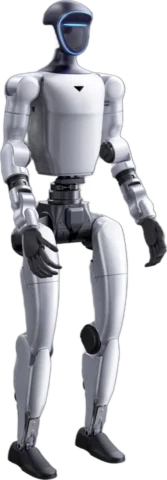
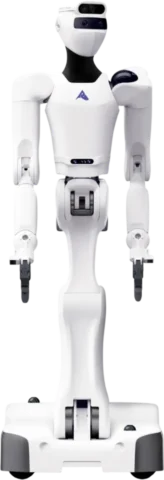
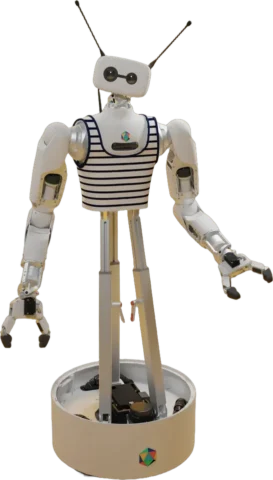
Galbot G1 vs ROBOTIS AI Worker FFW-SG2 vs Unitree H1
Price, availability in your region, size to scale and every spec side by side. Better values are marked; estimates never win.
Quick verdict
G1 wins 4 of the 6 specs where one robot is clearly better.
4
1
1
Choose G1 for
- AutonomyAutonomous tasks
- Carrying payload10 kg
- Payload per arm5 kg
- Runtime8 h
Choose AI Worker FFW-SG2 for
- Battery2,040 Wh
Choose H1 for
- Top speed5 m/s
Size to scale
- Adult175 cm
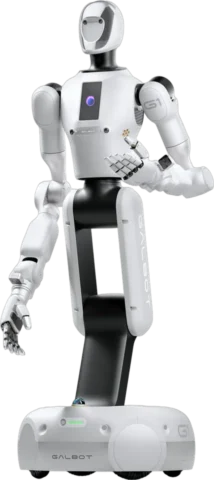 G1173 cm
- AI Worker FFW-SG2162 cm
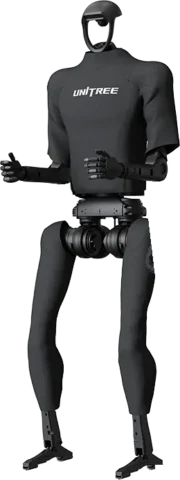 H1180 cm
All specs
| Spec | G1On request | AI Worker FFW-SG2On request | H1On request |
|---|---|---|---|
| Where you can get it | |||
| United States | Not available | Ships to you | Business only |
| European Union | Not available | Not available | Business only |
| United Kingdom | Not available | Not available | Business only |
| China | Ships to you | Not available | Business only |
| Japan and Korea | Not available | Not available | Business only |
| The rest of the world | Not available | Ships to you | Business only |
| Overview G1 1AI Worker FFW-SG2 0H1 0 | |||
| Status | Shipping | Shipping | Shipping |
| Announced | Jun 2024 | —Not published | Aug 2023 |
| Locomotion | Wheeled base | Wheeled base | Two legs |
| Form factor | Upper body | Upper body | Full-size humanoid |
| Autonomy | Autonomous tasksbetter | Partly autonomous | Programmed motions |
| Price | |||
| Price type | Quote only | Quote only | Quote only |
| Price note | No public price; JD.com listing in China | Quote only; tariffs included for US quotes | Price on request from Unitree sales; dexterous hands optional |
| Size & body | |||
| Height | 173 cm | 162 cm | 180 cm |
| Weight | 92.5 kg | 90 kg | 47 kg |
| Shoulder width | —Not published | —Not published | 57 cm |
| Vertical reach | 210 cm | —Not published | —Not published |
| Outer shell | —Not published | Aluminum, plastic | —Not published |
| Movement G1 0AI Worker FFW-SG2 0H1 1 | |||
| Degrees of freedom | 23calc. | 25 | 19calc. |
| DoF without hands | 21 | 23calc. | 19calc. |
| Walking speed | —Not published | 1.5 m/s | —Not published |
| Top speed | 1.5 m/s | —Not published | 5 m/sbetter |
| Peak joint torque | —Not published | —Not published | 360 N·m |
| Actuators | —Not published | Electric rotary | Electric rotary |
| Hands & handling G1 2AI Worker FFW-SG2 0H1 0 | |||
| Hands | Simple gripperbetter | Simple gripperbetter | None |
| DoF per hand | —Not published | 1 | —Not published |
| Carrying payload | 10 kgbetter | 6 kg | —Not published |
| Payload per arm | 5 kgbetter | 3 kg | —Not published |
| Peak lift | —Not published | 10 kg | —Not published |
| Battery & power G1 1AI Worker FFW-SG2 1H1 0 | |||
| Runtime | 8 hbetter | 6 h | —Not published |
| Battery | 1,440 Whcalc. | 2,040 Whbetter | 864 Wh |
| Battery swap | —Not published | —Not published | Swappable by hand |
| Charging | Plug-in charger | —Not published | —Not published |
| Charge time | 210 min | —Not published | —Not published |
| Charges itself | Yes | —Not published | —Not published |
| Sensors | |||
| Cameras | Head binocular camera, 4 torso RGB cameras | Stereolabs ZED Mini head camera, 2 × Intel RealSense D405 hand cameras | Intel RealSense D435i depth camera |
| Depth sensing | 2 wrist depth cameras; chassis 3D LiDAR and 8 ultrasonic sensors | RGBD cameras, 2 × LakiBeam 1 LiDAR (270°, up to 25 m) | Livox MID-360 3D LiDAR and Intel RealSense D435i depth camera |
| Audio | 2 × linear 4-mic arrays, 2 × 5 W speakers | —Not published | —Not published |
| Talks with people | Yes | —Not published | —Not published |
| Compute & AI | |||
| Onboard computer | NVIDIA AGX Orin 64GB | NVIDIA Jetson AGX Orin 32GB | Intel Core i5 (platform) and Intel Core i7 (user development); Orin NX optional |
| AI compute | 275 TOPS | —Not published | —Not published |
| AI model | Galbot AstraBrain embodied foundation model | —Not published | —Not published |
| Connectivity | Wi-Fi 2.4/5 GHz, Bluetooth 5.2, 2 × USB 3.0, HDMI | Ethernet, Wi-Fi router | —Not published |
| Software | |||
| SDK | Open SDK | Open SDK | Open SDK |
| Languages & frameworks | Python, C++ | ROS 2, Python, C++ | C++ and Python (unitree_sdk2) |
| Simulation models | Official G1 models in URDF, MJCF and USD | Gazebo, MuJoCo, Isaac Sim/Lab | URDF (unitree_ros); Isaac Gym and MuJoCo (unitree_rl_gym) |
| Over-the-air updates | —Not published | —Not published | Yes |
| Safety & compliance | |||
| Dust & water rating | IP54 | —Not published | —Not published |
| Emergency stop | Emergency stop button | —Not published | —Not published |
| Intended use | Retail, pharmacy and warehouse picking, industrial handling, education | Industrial manipulation, imitation learning and physical AI research | Civilian robot for research and development |
| Support | |||
| Warranty | 12 months | —Not published | —Not published |
A check marks the better value. Height and weight are context, not wins. Values marked "est.", "reported" or "calc." never count as wins. How we compare