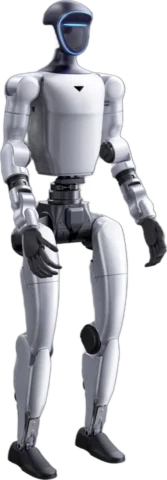
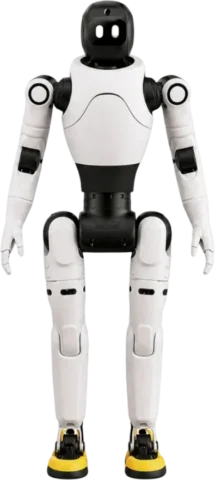
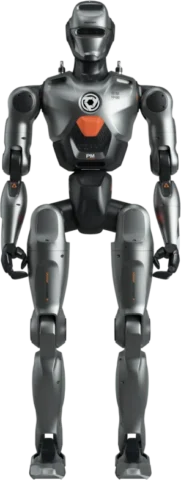
AgiBot X2 Ultra vs Unitree G1 EDU vs Unitree H1
Price, availability in your region, size to scale and every spec side by side. Better values are marked; estimates never win.
Quick verdict
X2 Ultra wins 3 of the 6 specs where one robot is clearly better.
3
1
2
Choose X2 Ultra for
- AutonomyPartly autonomous
- Degrees of freedom30
- AI compute157 TOPS
Choose G1 EDU for
- Price$43,900
Choose H1 for
- Top speed5 m/s
- Peak joint torque360 N·m
Size to scale
- Adult175 cm
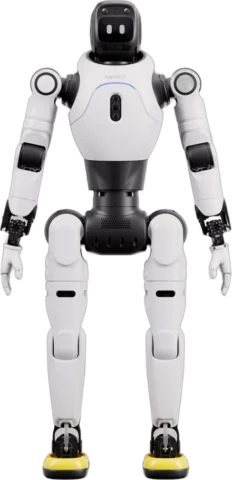 X2 Ultra131 cm
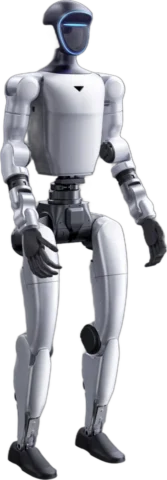 G1 EDU132 cm
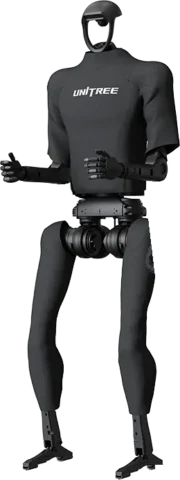 H1180 cm
All specs
| Spec | X2 Ultra$55,433 | G1 EDU$43,900 | H1On request |
|---|---|---|---|
| Where you can get it | |||
| United States | Ships to you$55,433 · Special order; hands extra | Ships to you$43,900 · RoboStore list price, USD, EDU Standard | Business only |
| European Union | Business only | Ships to youest. €47,900 · Special order; €38,115, VAT not stated | Business only |
| United Kingdom | Business only | Business only | Business only |
| China | Ships to youest. ¥445,000 · Official store: contact sales | Business only | Business only |
| Japan and Korea | Business only | Business only | Business only |
| The rest of the world | Ships to youest. $68,400 · Canada: CAD 71,427.14, special order | Business only | Business only |
| Overview X2 Ultra 1G1 EDU 0H1 0 | |||
| Status | Shipping | Shipping | Shipping |
| Announced | May 2025 | May 2024 | Aug 2023 |
| Locomotion | Two legs | Two legs | Two legs |
| Form factor | Compact humanoid | Compact humanoid | Full-size humanoid |
| Autonomy | Partly autonomousbetter | Programmed motions | Programmed motions |
| Price X2 Ultra 0G1 EDU 1H1 0 | |||
| Price | $55,433 | $43,900better | —Not published |
| Price type | Official price | Official price | Quote only |
| Price note | RobotShop list price (authorized distributor), special order; hands extra | List price of US distributor RoboStore for the EDU Standard; Unitree quotes EDU versions on request | Price on request from Unitree sales; dexterous hands optional |
| Size & body | |||
| Height | 131 cm | 132 cm | 180 cm |
| Weight | 39 kg | 35 kg | 47 kg |
| Shoulder width | 46 cm | —Not published | 57 cm |
| Movement X2 Ultra 1G1 EDU 0H1 2 | |||
| Degrees of freedom | 30better | 23 | 19calc. |
| DoF without hands | —Not published | 23 | 19calc. |
| Walking speed | 0.8 m/s | —Not published | —Not published |
| Top speed | 1.8 m/s | —Not published | 5 m/sbetter |
| Peak joint torque | 120 N·m | 120 N·m | 360 N·mbetter |
| Actuators | —Not published | —Not published | Electric rotary |
| Hands & handling | |||
| Hands | None | None | None |
| Payload per arm | —Not published | 3 kg | —Not published |
| Peak lift | 3 kg | —Not published | —Not published |
| Battery & power | |||
| Runtime | 2 h | 2 h | —Not published |
| Battery | —Not published | —Not published | 864 Wh |
| Battery swap | Swappable by hand | Swappable by hand | Swappable by hand |
| Charging | Plug-in charger | Plug-in charger | —Not published |
| Charge time | 90 min | —Not published | —Not published |
| Sensors | |||
| Cameras | Interactive RGB, front dual RGB and rear RGB cameras | Depth camera | Intel RealSense D435i depth camera |
| Depth sensing | 3D LiDAR and RGB-D camera | 3D LiDAR and depth camera | Livox MID-360 3D LiDAR and Intel RealSense D435i depth camera |
| Audio | Microphone array, wireless microphone, speaker | 4-microphone array, 5 W speaker | —Not published |
| Talks with people | Yes | —Not published | —Not published |
| Compute & AI X2 Ultra 1G1 EDU 0H1 0 | |||
| Onboard computer | 2 × RK3588 plus NVIDIA Jetson Orin NX | 8-core CPU plus NVIDIA Jetson Orin NX 16 GB module (RoboStore EDU Standard listing) | Intel Core i5 (platform) and Intel Core i7 (user development); Orin NX optional |
| AI compute | 157 TOPSbetter | 100 TOPS | —Not published |
| Connectivity | Wi-Fi, Bluetooth, 4G/5G, 2 × RJ45 | Wi-Fi 6, Bluetooth 5.2 | —Not published |
| Software | |||
| SDK | Open SDK | Open SDK | Open SDK |
| Languages & frameworks | Python, C++, ROS 2 (AimDK_X2) | C++, Python, ROS 2 | C++ and Python (unitree_sdk2) |
| Simulation models | MuJoCo motion-control simulation and URDF (AimDK_X2 docs) | MuJoCo and Isaac Lab (Unitree GitHub repositories) | URDF (unitree_ros); Isaac Gym and MuJoCo (unitree_rl_gym) |
| Over-the-air updates | Yes | Yes | Yes |
| Safety & compliance | |||
| Intended use | Guided tours, retail services, cultural and entertainment performances, research and education | Education, research and secondary development | Civilian robot for research and development |
| Support | |||
| Warranty | —Not published | 18 months | —Not published |
A check marks the better value. Height and weight are context, not wins. Values marked "est.", "reported" or "calc." never count as wins. How we compare